Industrial IoT and Business Operations · Study deck
Real-Time ISA-95: Determinism and Technology Mapping
A fast average link can still miss a control deadline when jitter spikes.
Ada is your guide for this deck.
After studying this chapter
Learning objectives
You will be able to:
- Distinguish hard, firm, and soft real-time deadlines.
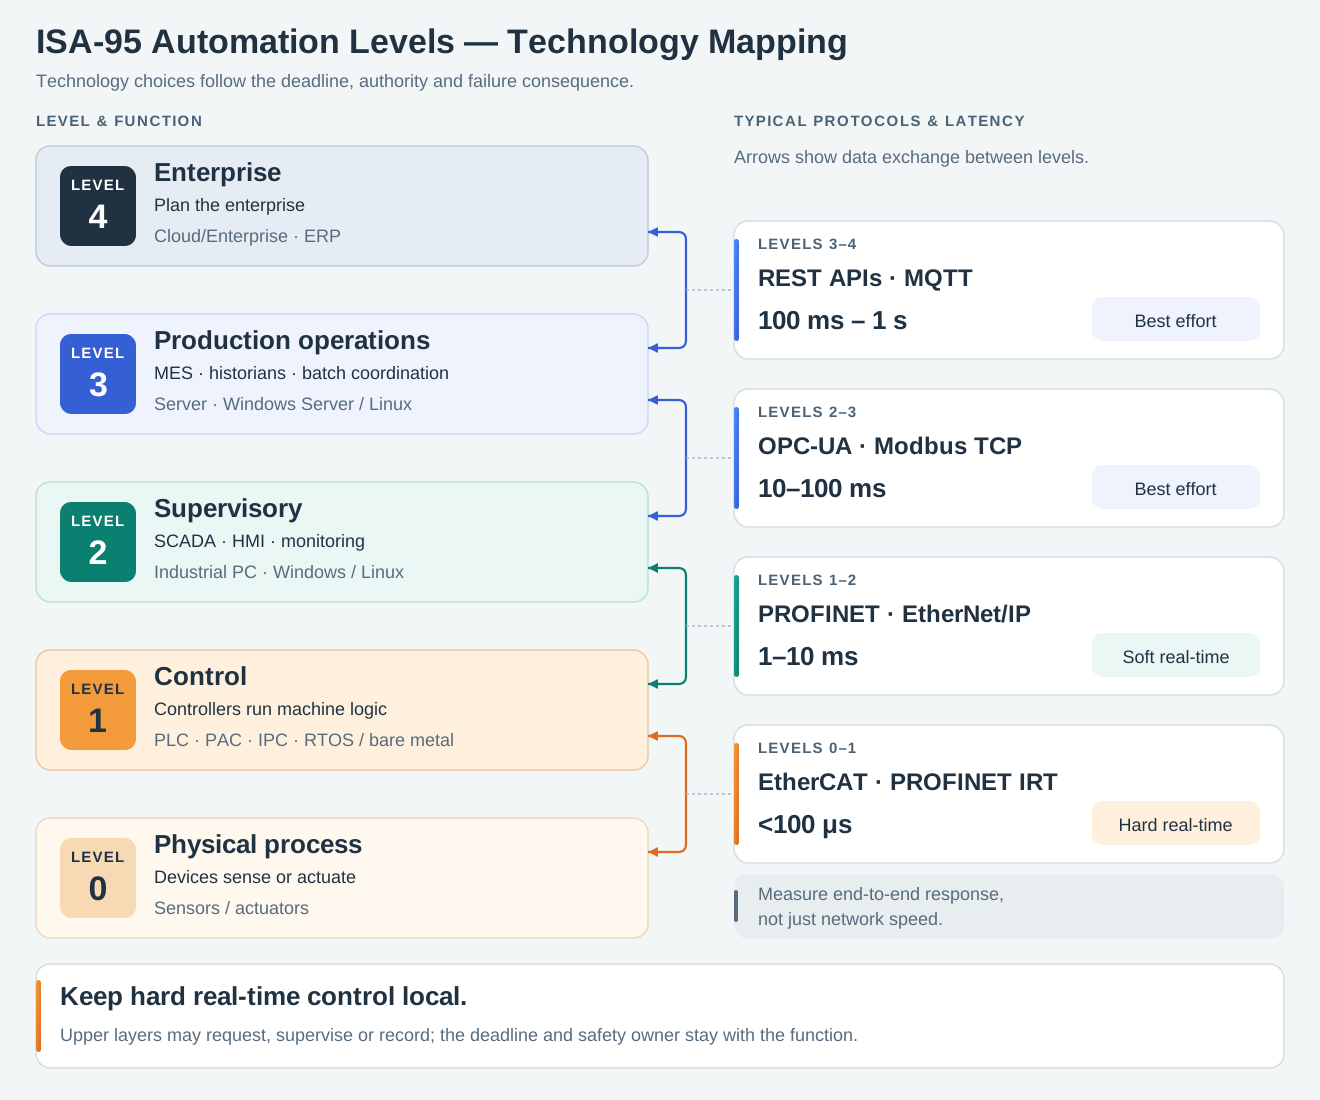
- Map jitter, synchronization, and network technology to ISA-95 levels.
- Explain: With the level timing ladder in place, the next question is what kind of promise each deadline needs.
- Explain: Missing a deadline is a system failure.
Major section
Determinism vs. Throughput
With the level timing ladder in place, the next question is what kind of promise each deadline needs.
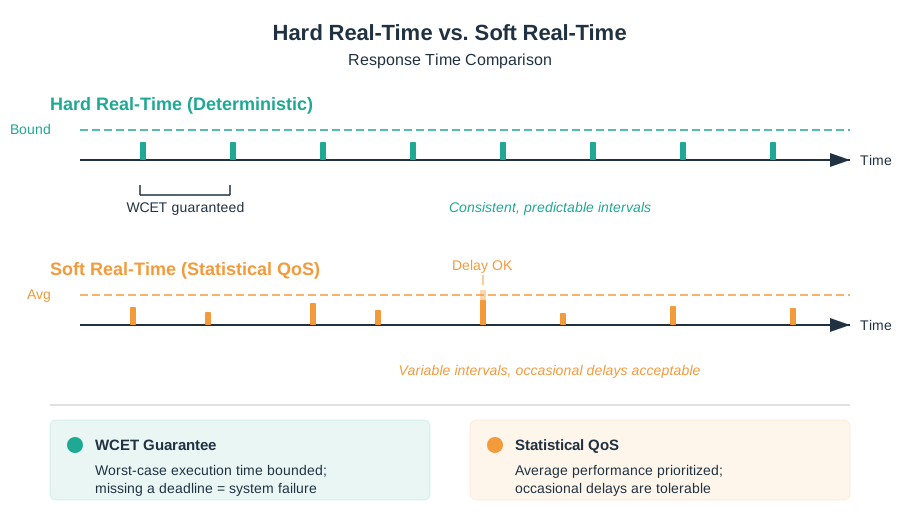
- Hard real-time: Response time is bounded and predictable.
- Some deadlines are hard failures; others are quality-of-service targets.
Major section
Hard vs Soft Real-Time Summary
Missing a deadline is a system failure.
- Soft real-time: Response time varies, and occasional delays degrade quality but do not stop the system.
- WCET guarantee: Hard real-time systems must prove worst-case execution time stays within the deadline.
- Worst-case execution time (WCET) must be bounded.
Major section
Hard vs Soft Real-Time Summary (continued)
Jitter must be minimal (<1μs for synchronized motion).
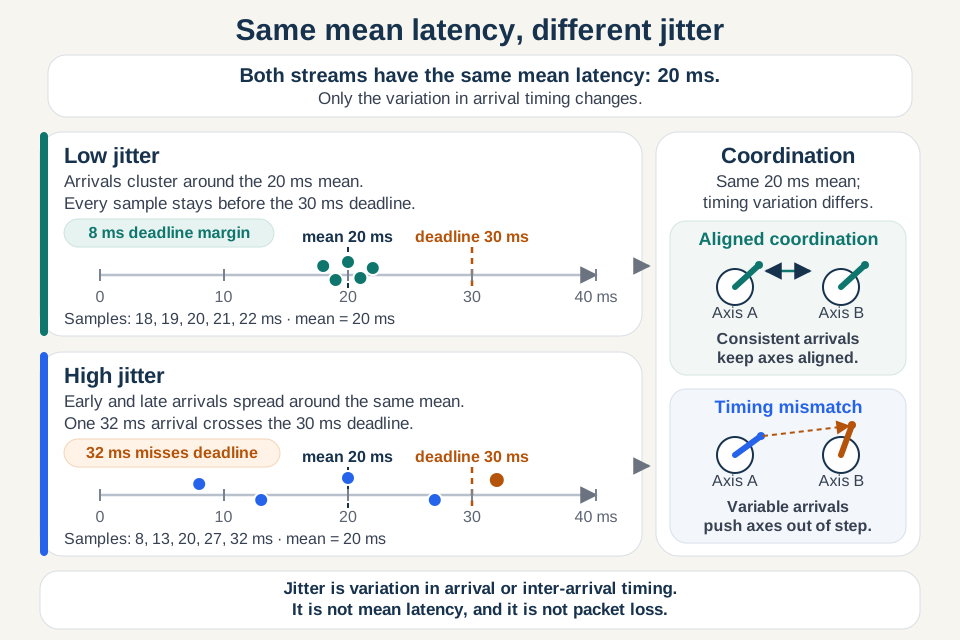
- Figure: Two streams can have the same average latency shows why an average latency figure can hide a missed deadline.
- The two axes in Figure: Two streams can have the same average latency are aligned on purpose, and both streams average 20 ms.
- On the lower axis the same average is built from arrivals at 8 ms and 32 ms, and the late one crosses the deadline.
Major section
Jitter and Synchronization
The panel on the right shows what that costs a machine: steady arrivals keep two axes in step, while variable arrivals push them out of position.
- The closing line is the definition to carry forward.
- Jitter is variation in arrival timing, not the mean and not packet loss.
Deck summary
Key takeaways
With the level timing ladder in place, the next question is what kind of promise each deadline needs.
- Missing a deadline is a system failure.
- Jitter must be minimal (<1μs for synchronized motion).
- The panel on the right shows what that costs a machine: steady arrivals keep two axes in step, while variable arrivals push them out of position.
Retrieval practice
Recall check 1 of 5

Ada says: answer from memory, then check your reasoning.
Q1A printing press requires a cycle time of 125 microseconds with maximum jitter of 1 microsecond. Which type of real-time guarantee does this require?
Show answer
Answer: A Hard real-time control bounds worst-case execution time and jitter.
Q2At which ISA-95 level would you place a SCADA system that displays alarm conditions to plant operators?
Show answer
Answer: A The ISA-95 stack separates field process, basic control, supervision, and operations.
Retrieval practice
Recall check 2 of 5

Ada says: answer from memory, then check your reasoning.
Q3Why is jitter often more critical than absolute latency for synchronized motion control?
Show answer
Answer: A For multi-axis control, variable command timing produces position error between axes.
Retrieval practice
Recall check 3 of 5

Ada says: answer from memory, then check your reasoning.
Q4A factory floor has three subsystems: (1) a servo motor requiring 250-microsecond cycle time, (2) a SCADA HMI refreshing every 500ms, and (3) a cloud dashboard updating every 30 seconds. Which protocol stack correctly matches each subsystem to the appropriate ISA-95 level?
Show answer
Answer: C EtherCAT can be engineered for sub-millisecond servo control at Level 0-1, PROFINET can support supervisory factory traffic, and MQTT fits best-effort dashboard publishing when the control boundary is protected.
Retrieval practice
Recall check 4 of 5

Ada says: answer from memory, then check your reasoning.
Q5An engineer needs to connect 100 PLCs to a Manufacturing Execution System (MES) for production scheduling. Which protocol and ISA-95 level boundary does this cross?
Show answer
Answer: A PLCs operate in basic control, while MES sits at operations Level 3.
Retrieval practice
Recall check 5 of 5

Ada says: answer from memory, then check your reasoning.
Q6A factory floor network uses air-gapped segmentation. Which ISA-95 level does this practice primarily protect?
Show answer
Answer: A Air-gapped segmentation separates critical field and basic-control networks from less deterministic enterprise traffic and attack paths.
Print reference
Answers 1 of 2
Answer key.
- A · Hard real-time control bounds worst-case execution time and jitter.
- A · The ISA-95 stack separates field process, basic control, supervision, and operations.
- A · For multi-axis control, variable command timing produces position error between axes.
- C · EtherCAT can be engineered for sub-millisecond servo control at Level 0-1, PROFINET can support supervisory factory traffic, and MQTT fits best-effort dashboard publishing when the control boundary is protected.
Print reference
Answers 2 of 2
Answer key.
- A · PLCs operate in basic control, while MES sits at operations Level 3.
- A · Air-gapped segmentation separates critical field and basic-control networks from less deterministic enterprise traffic and attack paths.